顯示具有 Servo 標籤的文章。 顯示所有文章

2023年11月1日 星期三

Balance Ball and Beam Control system

Purpose:
Balance ball and beam control system.
This project is constructed using the HC-SR04 Ultrasonic Sensor to detect the position of the sphere and using the PID principle to control the Servo motor to move the object to the specified position.
這個專案在建構利用HC-SR04 Ultrasonic Sensor偵測球體位置並利用PID原理, 控制Servo motor移動物體到指定位置.
The control objective is to control the torque applied at the pivot of the beam, such that the ball can roll on the beam and track a desired trajectory. The torque causes thus a change of the beam angle and a movement in the position of the ball.
控制目標是控制施加在橫樑樞軸處的扭矩, 使得球可以在橫樑上滾動並追蹤期望的軌跡. 因此, 扭矩導致承載面角度的變化和球位置的移動.
Fundamental:
網路關於PID控制有很多介紹, 可自行參考. 
My Blog artical:
從ESP32 with HC-SR04 Ultrasonic Sensor 這篇文章開始接觸Ultrasonic Sensor
進而利用Ultrasonic Sensor做一些應用專題如:
其中參閱很多網路先進的文章再融入自己的想法, 實際將其做出, 收益頗多!

BOM(Bill of Material):

圖一: Woods
圖二: Servo Motor MG995
圖三:軸承Bearing
圖四: Wood with Bearing
圖五: HC-SR04 Ultrasonic Sensor
圖六: Ruler
圖七: ESP32

圖八: glue 熱熔膠
圖九: PVC Tube


Circuit:

YouTube Demo:
ESP32 Code:
#include <ESP32Servo.h>
#include<PID_v1.h>
//#include <Servo.h>
//--------- Flag structure --------------------------------------
typedef struct _vFlag
{
  uint8_t BTFlag = 0;
  uint8_t DC_Flag = 0;
  uint8_t CANFlag = 0;
  uint8_t I2C_Flag = 0;
  uint8_t BMP180Flag = 0;
  uint8_t HCSR04Flag = 1;
  uint8_t LEDFlag = 0;
  uint8_t initial_Flag = 0;
  uint8_t FunctionFlag = 3;
  uint8_t SendFlag = 0;
  uint8_t BMPCnt = 0;
} vFlag;
vFlag *flag_Ptr;
vFlag flag;
//------LED------------------
#define LED_BUILTIN 2
//------------------------------------------------
Servo myservo;  // create servo object to control a servo
// Recommended PWM GPIO pins on the ESP32 include 2,4,12-19,21-23,25-27,32-33
int servoPin = 13;
//-----hcsr04 sensor------------------
#define TRIGPIN_PIN  12
#define ECHO_PIN    14
long duration;
int distance;
int set=25,neg=5,pos=45,base=67;
double StartAngle = 90;     //Angle of servo when beam is parallel to the ground
//-------------PID ------------------------
float Kp = 0.8;         //Initial Proportional Gain
float Ki = 0.005;              //Initial Integral Gain
float Kd = 0.3;             //Intitial Derivative Gain

double Setpoint, Input, Output, ServoOutput;                                    
PID myPID(&Input, &Output, &Setpoint, Kp, Ki, Kd, REVERSE);  
//--------------------------------------------
unsigned long currentMillis = 0;
unsigned long previousMillis = 0;
int interval = 1000;
//----------uart--------------
#define LINE_BUFFER_LENGTH 64
//--------- uart structure --------------------------------------
typedef struct _vUart
{
  char c;
  int lineIndex = 0;
  int line1Index = 0;
  int BTlineIndex = 0;
  bool lineIsComment;
  bool lineSemiColon;
  char line[128];
  char BTline[20];
  String inputString;
  String BTinputString;
  String S1inputString;
  int V[16];
  char ctemp[30];
  char I2C_Data[80];
  int DC_Spped = 50;
  float Voltage[16];
  int Buffer[128];
  int StartCnt = 0;
  int ReadCnt = 0;
  int sensorValue = 0;
} vUart;
vUart *Uart_Ptr;
vUart Uart;

//-------------------------------------------------
void setup()
{
  Serial.begin(9600);
  Serial.println(F("init"));
  pinMode(LED_BUILTIN, OUTPUT);
  pinMode(TRIGPIN_PIN, OUTPUT);
  pinMode(ECHO_PIN, INPUT);
  pinMode(servoPin, OUTPUT);
  //myservo.setPeriodHertz(50);    // standard 50 hz servo
  //myservo.attach(servoPin, 500, 2400); // attaches the servo on pin 13 to the servo object
  myservo.attach(servoPin);
  myservo.write(StartAngle);
  Input = readPosition();  
  myPID.SetMode(AUTOMATIC);           //Set PID object myPID to AUTOMATIC
  myPID.SetOutputLimits(-25,25);      //Set Output limits to -80 and 80 degrees.
}
//-----------------------------------------
void loop()
{
  Serial.print(F("Main at core:"));
  Serial.println(xPortGetCoreID());
  while(1)
  {
    if(flag.HCSR04Flag==1)
    {
      Setpoint = 25;
      Input = readPosition();
      myPID.Compute();
      //ServoOutput=base+Output;
      //myservo.write(ServoOutput);
      Serial.print(Input); Serial.print(" "); Serial.println(Output);
      if (Output>0)
      {
        ServoOutput=92+Output;
        myservo.write(ServoOutput);
      }
      else if(Output<0)
      {
        ServoOutput=60+Output;
        myservo.write(ServoOutput);
      }
    }
   
    if(flag.LEDFlag == 1)
    {
      digitalWrite(LED_BUILTIN, HIGH);
      vTaskDelay(300);
      digitalWrite(LED_BUILTIN, LOW);
      vTaskDelay(300);
    }
    while (Serial.available() > 0)
    {
      Uart.c = Serial.read();

      if ((Uart.c == '\n') || (Uart.c == '\r'))
      { // End of line reached
        if (Uart.lineIndex > 0)
        { // Line is complete. Then execute!
          Uart.line[Uart.lineIndex] = '\0'; // Terminate string
          //Serial.println( F("Debug") );
          //Serial.println( Uart.inputString );
          processCommand(Uart.line); // do something with the command
         
          Uart.lineIndex = 0;
          Uart.inputString = "";
        }
        else
        {
          // Empty or comment line. Skip block.
        }
        Uart.lineIsComment = false;
        Uart.lineSemiColon = false;
        Serial.println(F("ok>"));
      }
      else
      {
        //Serial.println( c );
        if ((Uart.lineIsComment) || (Uart.lineSemiColon))
        {
          if (Uart.c == ')')
            Uart.lineIsComment = false; // End of comment. Resume line.
        }
        else
        {
          if (Uart.c == '/')
          { // Block delete not supported. Ignore character.
          }
          else if (Uart.c == '~')
          { // Enable comments flag and ignore all characters until ')' or EOL.
            Uart.lineIsComment = true;
          }
          else if (Uart.c == ';')
          {
            Uart.lineSemiColon = true;
          }
          else if (Uart.lineIndex >= LINE_BUFFER_LENGTH - 1)
          {
            Serial.println("ERROR - lineBuffer overflow");
            Uart.lineIsComment = false;
            Uart.lineSemiColon = false;
          }
          else if (Uart.c >= 'a' && Uart.c <= 'z')
          { // Upcase lowercase
            Uart.line[Uart.lineIndex] = Uart.c - 'a' + 'A';
            Uart.lineIndex = Uart.lineIndex + 1;
            Uart.inputString += (char)(Uart.c - 'a' + 'A');
          }
          else
          {
            Uart.line[Uart.lineIndex] = Uart.c;
            Uart.lineIndex = Uart.lineIndex + 1;
            Uart.inputString += Uart.c;
          }
        }
      }
    } //while (Serial.available() > 0)
  }
}
//---------------------------------------
float readPosition()
{
  if(flag.HCSR04Flag==1)
  {
    pinMode(TRIGPIN_PIN, OUTPUT);
    digitalWrite(TRIGPIN_PIN, LOW);  
    delayMicroseconds(5);  
    digitalWrite(TRIGPIN_PIN, HIGH);
    delayMicroseconds(10);  
    digitalWrite(TRIGPIN_PIN, LOW);  
    pinMode(ECHO_PIN, INPUT);
    duration= pulseIn(ECHO_PIN, HIGH);
    distance= duration/29/2;

  return (distance);  
  }
}
//----------------------------------------
void processCommand(char *data)
{
  int len, xlen, ylen, zlen, alen;
  int tempDIO;
  String stemp;

  len = Uart.inputString.length();
  //---------------------------------------
  if (strstr(data, "VER") != NULL)
  {
    Serial.println(F("ESP32_20231031"));
  }
   if (strstr(data, "HCSR04_ON") != NULL)
  {
    flag.HCSR04Flag = 1;
    flag.LEDFlag = 0;
    Serial.println(F("HCSR04_ON"));
  }
  if (strstr(data, "HCSR04_OFF") != NULL)
  {
    flag.HCSR04Flag = 0;
    flag.LEDFlag = 1;
    Serial.println(F("HCSR04_OFF"));
  }  
  if (strstr(data, "SERVO_90")!= NULL)
  {
    Serial.println(F("SERVO_90"));
    myservo.write(90);
  }
  if (strstr(data, "SERVO_50")!= NULL)
  {
    Serial.println(F("SERVO_50"));
    myservo.write(50);
  }
  if (strstr(data, "SERVO_70")!= NULL)
  {
    Serial.println(F("SERVO_70"));
    myservo.write(70);
  }
  if (strstr(data, "SERVO_100")!= NULL)
  {

    Serial.println(F("SERVO_100"));
    myservo.write(100);
  }
  if (strstr(data, "SERVO_120")!= NULL)
  {
    Serial.println(F("SERVO_120"));
    myservo.write(120);
  }
  if (strstr(data, "SERVO_140")!= NULL)
  {
    Serial.println(F("SERVO_140"));
    myservo.write(140);
  }
}
//-----------------------------------------

2023年9月10日 星期日

Inductive trash can with ESP32

Purpose:

利用手上ESP32板子為主架構搭配PIR HC-SR505 sensor感應去控制servo motor旋轉角度另添加一塊充電模組可以完成一個充電式感應垃圾桶!!

Using the ESP32 board as the main structure with the PIR HC-SR505 sensor to control the rotation angle of the servo motor, and adding a charging module to complete a rechargeable inductive trash can!!

BOM:

Figure1 PIR HC-SR505

Figure2 充電鋰電池

Figure3 ESP32
                                                                   

Figure4 充電板
Circuit:
Figure5 整體架構
YouTube Demo:
演示影片
Code Introduce:
#include <ESP32Servo.h>
#include <BluetoothSerial.h>
//--------- Flag structure --------------------------------------
typedef struct _vFlag
{
  uint8_t LEDFlag=1;
  uint8_t BTFlag = 0;
  uint8_t ServoFlag = 0;
  uint8_t PIR_Flag = 1;
  uint8_t PIR_status = 0;
} vFlag;
vFlag *flag_Ptr;
vFlag flag;
//----------uart--------------
#define LINE_BUFFER_LENGTH 64
//--------- uart structure --------------------------------------
typedef struct _vUart
{
  char c;
  int lineIndex = 0;
  int line1Index = 0;
  int BTlineIndex = 0;
  bool lineIsComment;
  bool lineSemiColon;
  char line[128];
  char BTline[20];
  String inputString;
  String BTinputString;
  String S1inputString;
  int V[16];
  char ctemp[30];
  char I2C_Data[80];
  int DC_Spped = 50;
  float Voltage[16];
  int Buffer[128];
  int StartCnt = 0;
  int ReadCnt = 0;
  int sensorValue = 0;
} vUart;
vUart *Uart_Ptr;
vUart Uart;
//------------------------------------------------
#define LED_BUILTIN 2
BluetoothSerial SerialBT;
//------------------------------------------------
Servo myservo;  // create servo object to control a servo
// Recommended PWM GPIO pins on the ESP32 include 2,4,12-19,21-23,25-27,32-33
int servoPin = 13;
//-----------------------
int inPin = 22;  //PIR pin
//-------------------------------------------------
void setup()
{
  Serial.begin(9600);
  Serial.println(F("init"));
  pinMode(LED_BUILTIN, OUTPUT);
  pinMode(inPin, INPUT);
  SerialBT.begin("BT_Servo");    // BTName
  myservo.setPeriodHertz(50);    // standard 50 hz servo
  myservo.attach(servoPin, 500, 2400); // attaches the servo on pin 13 to the servo object
  myservo.write(0);
}
//-----------------------------------------
void loop()
{
  Serial.print(F("Main at core:"));
  Serial.println(xPortGetCoreID());
  while(1)
  {
    if(flag.LEDFlag == 1)  //flash LED
    {
      digitalWrite(LED_BUILTIN, HIGH);
      vTaskDelay(300);
      digitalWrite(LED_BUILTIN, LOW);
      vTaskDelay(300);
    }
    if (flag.PIR_Flag == 1)  //start PIR detect
    {
      Serial.println(flag.PIR_status);
      if(digitalRead(inPin) == HIGH)
      {  
        if(flag.PIR_status==0)
        {
          Serial.println("Presence detected");
          myservo.write(100);
          flag.PIR_status=1;
          vTaskDelay(20);    
        }
      }
      else
      {
        if(flag.PIR_status==1)
        {
          Serial.println("No detected");
          myservo.write(0);
          flag.PIR_status=0;  
        }
      }
    }
    while (Serial.available() > 0)
    {
      Uart.c = Serial.read();

      if ((Uart.c == '\n') || (Uart.c == '\r'))
      { // End of line reached
        if (Uart.lineIndex > 0)
        { // Line is complete. Then execute!
          Uart.line[Uart.lineIndex] = '\0'; // Terminate string
          //Serial.println( F("Debug") );
          //Serial.println( Uart.inputString );
          processCommand(Uart.line); // do something with the command
          //傳輸給藍芽
          SerialBT.println(Uart.line);
         
          Uart.lineIndex = 0;
          Uart.inputString = "";
        }
        else
        {
          // Empty or comment line. Skip block.
        }
        Uart.lineIsComment = false;
        Uart.lineSemiColon = false;
        Serial.println(F("ok>"));
      }
      else
      {
        //Serial.println( c );
        if ((Uart.lineIsComment) || (Uart.lineSemiColon))
        {
          if (Uart.c == ')')
            Uart.lineIsComment = false; // End of comment. Resume line.
        }
        else
        {
          if (Uart.c == '/')
          { // Block delete not supported. Ignore character.
          }
          else if (Uart.c == '~')
          { // Enable comments flag and ignore all characters until ')' or EOL.
            Uart.lineIsComment = true;
          }
          else if (Uart.c == ';')
          {
            Uart.lineSemiColon = true;
          }
          else if (Uart.lineIndex >= LINE_BUFFER_LENGTH - 1)
          {
            Serial.println("ERROR - lineBuffer overflow");
            Uart.lineIsComment = false;
            Uart.lineSemiColon = false;
          }
          else if (Uart.c >= 'a' && Uart.c <= 'z')
          { // Upcase lowercase
            Uart.line[Uart.lineIndex] = Uart.c - 'a' + 'A';
            Uart.lineIndex = Uart.lineIndex + 1;
            Uart.inputString += (char)(Uart.c - 'a' + 'A');
          }
          else
          {
            Uart.line[Uart.lineIndex] = Uart.c;
            Uart.lineIndex = Uart.lineIndex + 1;
            Uart.inputString += Uart.c;
          }
        }
      }
    } //while (Serial.available() > 0)
    while (SerialBT.available())
    {
      //讀取藍芽資料
      String BTdata = SerialBT.readString();
      //顯示在序列視窗
      Serial.println(BTdata);
      //char charBuf[BTdata.length() + 1];
      //BTdata.toCharArray(charBuf, BTdata.length());
      BTprocessCommand(BTdata); // do something with the command
      //processCommand(charBuf); // do something with the command
    }//while (BT.available())

  }
}
void BTprocessCommand(String data)
{
  if (data == "100")
  {
    Serial.println(F("SERVO_100"));
    myservo.write(100);
  }
  if (data == "10")
  {
    Serial.println(F("SERVO_10"));
    myservo.write(10);
    //myservo.detach();
  }
  if (data == "180")
  {
    Serial.println(F("SERVO_180"));
    myservo.write(180);
  }
  if (data == "50")
  {
    Serial.println(F("SERVO_50"));
    myservo.write(50);
    //myservo.detach();
  }
}
//----------------------------------------
void processCommand(char *data)
{
  int len, xlen, ylen, zlen, alen;
  int tempDIO;
  String stemp;

  len = Uart.inputString.length();
  //---------------------------------------
  if (strstr(data, "VER") != NULL)
  {
    Serial.println(F("ESP32_20230710"));
  }
  //-------------- Servo --------------------
  if (strstr(data, "SERVO_5")!= NULL)
  {
    Serial.println(F("SERVO_5"));
    myservo.write(5);
    //myservo.detach();
  }
  if (strstr(data, "SERVO_10")!= NULL)
  {
    Serial.println(F("SERVO_10"));
    myservo.write(10);
  }
  if (strstr(data, "SERVO_50")!= NULL)
  {
    Serial.println(F("SERVO_50"));
    myservo.write(50);
  }
  if (strstr(data, "SERVO_100")!= NULL)
  {

    Serial.println(F("SERVO_100"));
    myservo.write(100);
  }
  if (strstr(data, "SERVO_180")!= NULL)
  {
    Serial.println(F("SERVO_180"));
    myservo.write(180);
  }
  if (strstr(data, "SERVO_270")!= NULL)
  {
    Serial.println(F("SERVO_270"));
    myservo.write(270);
  }
}
//------------------------------------------


2023年8月6日 星期日

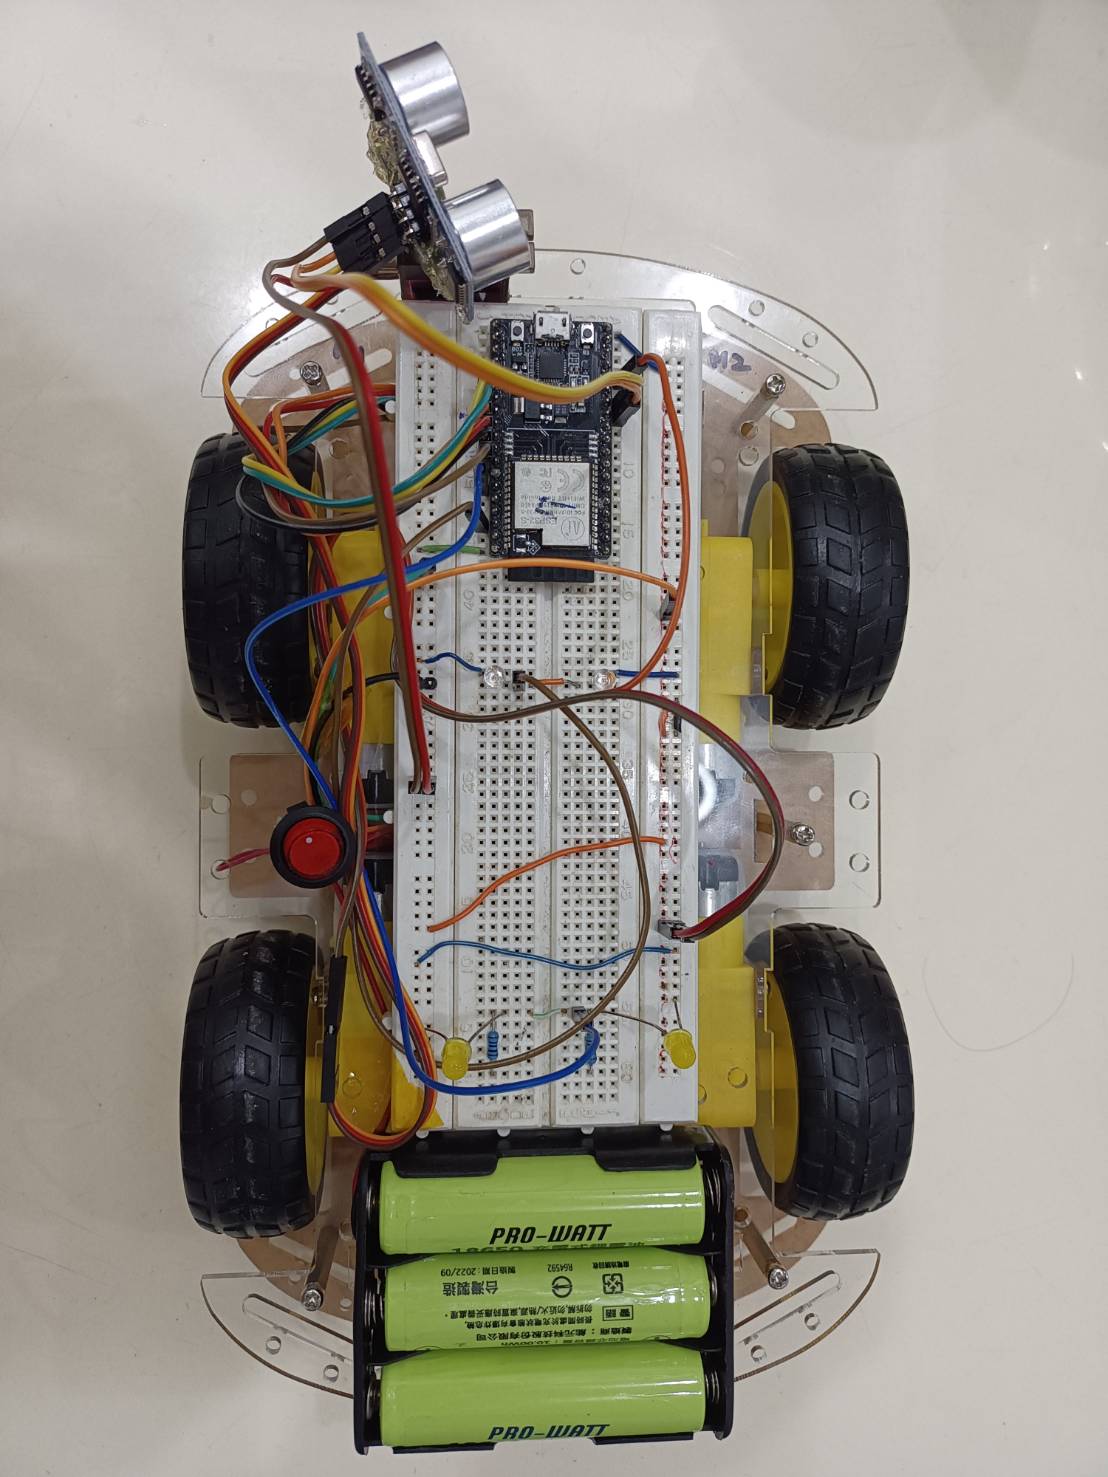
ESP32 Obstacle Avoiding Robot Car

Purpose:

Refer to the previous two articles (ESP32 Bluetooth Remote Control Car -DIY) and (ESP32 with HC-SR04 Ultrasonic Sensor)

You can build your own ESP32 based obstacle avoiding robot car. The car uses a servo mounted ultrasonic sensor to detect objects in front of and on either side of the car and an L298N DC motor driver shield to drive four geared motors, one on each wheel.

Download Library
robojax_L298N-DC-Motor_library
https://robojax.com/learn/arduino/robojax_L298N-DC-Motor_library.zip

Circuit:


YouTubeDemo:

CodeIntroduce:

#include <Robojax_L298N_DC_motor.h>
#include <BluetoothSerial.h>
#include <ESP32Servo.h>
//--------- Flag structure --------------------------------------
typedef struct _vFlag
{
  uint8_t BTFlag = 0;
  uint8_t L298NFlag = 0;
  uint8_t HCSR04Flag = 1;
  uint8_t LEDFlag = 1;
  uint8_t ServoFlag = 0;
  uint8_t initial_Flag = 0;
  uint8_t FunctionFlag = 0;
  uint8_t back_light_Flag = 0;
  uint8_t front_light_Flag = 0;
} vFlag;
vFlag *flag_Ptr;
vFlag flag;
//---------BT--------------------
BluetoothSerial SerialBT;
//---------------servo------------------------------
Servo myservo;  // create servo object to control a servo
// Recommended PWM GPIO pins on the ESP32 include 2,4,12-19,21-23,25-27,32-33
#define servoPin 13
//------LED------------------
#define LED_BUILTIN 2
//-------------L298---------------------------------------------------
// motor 1 settings
#define CHA 0
#define ENA 4 // this pin must be PWM enabled pin if Arduino board is used
#define IN1 16
#define IN2 17
// motor 2 settings
#define IN3 18
#define IN4 19
#define ENB 5// this pin must be PWM enabled pin if Arduino board is used
#define CHB 1

const int CCW = 2; // do not change
const int CW  = 1; // do not change

#define motor1 1 // do not change
#define motor2 2 // do not change

// for two motors without debug information // Watch video instruciton for this line: https://youtu.be/2JTMqURJTwg
Robojax_L298N_DC_motor motors(IN1, IN2, ENA, CHA,  IN3, IN4, ENB, CHB);
//------Bluetooth RC Controller Define ----
#define back_light 21
#define front_light 22
//-----hcsr04 sensor------------------
#define TRIGPIN_PIN 12
#define ECHO_PIN 14
long duration;
unsigned long currentMillis = 0;
//----------global ------------------------
#define MAX_DISTANCE 200
#define MAX_SPEED 190 // Sets speed of DC motors
int speedSet = 0;
int distance = 60;
int distanceR = 0;
int distanceL = 0;
//--------- uart structure --------------------------------------
//----------uart--------------
#define LINE_BUFFER_LENGTH 64
typedef struct _vUart
{
  char c;
  int lineIndex = 0;
  int line1Index = 0;
  int BTlineIndex = 0;
  bool lineIsComment;
  bool lineSemiColon;
  //char *line;
  char line[128];
  //char line1[128];
  char BTline[20];
  //char R_line[20];
  //char L_line[20];
  String inputString;
  String BTinputString;
  String S1inputString;
  int V[16];
  char ctemp[30];
  char I2C_Data[80];
  int DC_Spped = 50;
  float Voltage[16];
  int Buffer[128];
  int StartCnt = 0;
  int ReadCnt = 0;
  int sensorValue = 0;
} vUart;
vUart *Uart_Ptr;
vUart Uart;
//-------------------------------------
TaskHandle_t huart;
TaskHandle_t hfunction;

void vUARTTask(void *pvParameters);
void vFunctionTask(void *pvParameters);
//------------------------------------------------------------------------------
void initial()
{
  Serial.println(F("Create Task"));
  //----------------------------------------------------------------------
  xTaskCreatePinnedToCore(
    vUARTTask, "UARTTask" // A name just for humans
    ,
    1024 // This stack size can be checked & adjusted by reading the Stack Highwater
    ,
    NULL, 3 // Priority, with 3 (configMAX_PRIORITIES - 1) being the highest, and 0 being the lowest.
    ,
    &huart //handle
    ,
    0);

  xTaskCreatePinnedToCore(
    vFunctionTask, "FunctionTask"
    ,
    1024 // Stack size
    ,
    NULL, 1 // Priority
    ,
    &hfunction
    ,
    1);

  //----------------------------------------------------------------------

  //----------------------------------------------------------------------
}

void Forward()
{  
  //motors.rotate(motor1, 60, CCW);
  //motors.rotate(motor2, 60, CCW);
  digitalWrite(IN1, LOW);
  digitalWrite(IN2, HIGH);
  analogWrite(ENA, 100);
  digitalWrite(IN3, LOW);
  digitalWrite(IN4, HIGH);
  analogWrite(ENB, 100);
}

void Reverse(){
  //motors.rotate(motor2, 70, CW);
  //motors.rotate(motor1, 70, CW);
  digitalWrite(IN1, HIGH);
  digitalWrite(IN2, LOW);
  analogWrite(ENA, 100);
  digitalWrite(IN3, HIGH);
  digitalWrite(IN4, LOW);
  analogWrite(ENB, 100);
}
void Left()
{
  //motors.rotate(motor1, 70, CW);
  //motors.rotate(motor2, 70, CCW); //LF
  digitalWrite(IN1, LOW);
  digitalWrite(IN2, HIGH);
  analogWrite(ENA, 100);
}
void Right()
{
  digitalWrite(IN3, LOW);
  digitalWrite(IN4, HIGH);
  analogWrite(ENB, 100);
  //motors.rotate(motor1, 70, CCW); //RF
  //motors.rotate(motor2, 70, CW);
}
void Stop()
{
  motors.brake(1);
  motors.brake(2);
  //myservo.detach();
}
//-------------------------------------------------
void setup()
{
  Serial.begin(9600);
  Serial.println(F("init"));
  initial();
  SerialBT.begin("BT_L298N");
  myservo.setPeriodHertz(50);    
  myservo.attach(servoPin, 500, 2400);
  pinMode(LED_BUILTIN, OUTPUT);
  pinMode(TRIGPIN_PIN, OUTPUT);
  pinMode(ECHO_PIN, INPUT);
  pinMode(IN1, OUTPUT);
  pinMode(IN2, OUTPUT);
  pinMode(IN3, OUTPUT);
  pinMode(IN4, OUTPUT);
  pinMode(ENA, OUTPUT);
  pinMode(ENB, OUTPUT);
  pinMode(back_light, OUTPUT);
  pinMode(front_light, OUTPUT);
  motors.begin();
  myservo.write(90);
}
//-----------------------------------------
void loop()
{
  Serial.print(F("Main at core:"));
  Serial.println(xPortGetCoreID());
  while(1)
  {
    if(flag.HCSR04Flag==1)
    {
      if(distance<=35)
      {
        Stop();
        delay(200);
        Reverse();
        delay(400);
        Stop();
        delay(100);
        flag.HCSR04Flag=2;
        delay(2000);
        flag.HCSR04Flag=3;
        delay(2000);
        flag.HCSR04Flag=1;
        if ((distanceR >= distanceL) )
        {
          Left();
          delay(700);
          Stop();
          delay(200);
          flag.HCSR04Flag=1;
        }
        else
        {
          Right();
          delay(700);
          Stop();
          delay(200);
          flag.HCSR04Flag=1;
        }
        myservo.write(90);
        delay(1000);
      }
      else
      {
        flag.HCSR04Flag=1;
        Forward();
        delay(100);
        Stop();
        delay(30);
      }      
    }
    vTaskDelay(1);
  }
}
//----------------------------------------
void processCommand(char *data)
{
  int len, xlen, ylen, zlen, alen;
  int tempDIO;
  String stemp;

  len = Uart.inputString.length();
  //---------------------------------------
  if (strstr(data, "VER") != NULL)
  {
    Serial.println(F("ESP32_20230710"));
  }
  //-------------- HCSR04 --------------------
  if (strstr(data, "HCSR04_ON") != NULL)
  {
    flag.HCSR04Flag = 1;
    Serial.println(F("HCSR04_ON"));
  }
  if (strstr(data, "HCSR04_OFF") != NULL)
  {
    flag.HCSR04Flag = 0;
    Serial.println(F("HCSR04_OFF"));
  }  
  //----------------L298N-----------
  if (strstr(data, "F") != NULL)
  {
    Serial.println(F("Forward"));
    Forward();
    //forward();
   
  }
  if (strstr(data, "L") != NULL)
  {
    Serial.println(F("Left"));
    Left();
  }
  if (strstr(data, "R") != NULL)
  {
    Serial.println(F("Right"));
    Right();
  }
  if (strstr(data, "B") != NULL)
  {
    Serial.println(F("Reverse"));
    Reverse();
    //backward();
  }
  if (strstr(data, "S") != NULL)
  {
    Serial.println(F("Stop"));
    Stop();
  }
  //-----------------servo----------
  //-------------- Servo --------------------
  if (strstr(data, "SERVO_5")!= NULL)
  {
    Serial.println(F("SERVO_5"));
    myservo.write(5);
    //myservo.detach();
  }
  if (strstr(data, "SERVO_10")!= NULL)
  {
    Serial.println(F("SERVO_10"));
    myservo.write(10);
  }
  if (strstr(data, "SERVO_20")!= NULL)
  {
    Serial.println(F("SERVO_20"));
    myservo.write(20);
  }
  if (strstr(data, "SERVO_30")!= NULL)
  {
    Serial.println(F("SERVO_30"));
    myservo.write(30);
  }
  if (strstr(data, "SERVO_50")!= NULL)
  {
    Serial.println(F("SERVO_50"));
    myservo.write(50);
  }
  if (strstr(data, "SERVO_80")!= NULL)
  {
    Serial.println(F("SERVO_80"));
    myservo.write(80);
  }
  if (strstr(data, "SERVO_90")!= NULL)
  {
    Serial.println(F("SERVO_90"));
    myservo.write(90);
  }
  if (strstr(data, "SERVO_100")!= NULL)
  {
    Serial.println(F("SERVO_100"));
    myservo.write(100);
  }
  if (strstr(data, "SERVO_120")!= NULL)
  {
    Serial.println(F("SERVO_120"));
    myservo.write(120);
  }
  if (strstr(data, "SERVO_140")!= NULL)
  {
    Serial.println(F("SERVO_140"));
    myservo.write(140);
  }
  if (strstr(data, "SERVO_150")!= NULL)
  {
    Serial.println(F("SERVO_150"));
    myservo.write(150);
  }
}
//-----------------------------------------
//-------------------BT-----------------
void BTprocessCommand(String data)
{
  if (data =="FS")
  {
    Serial.println(F("Forward"));
    Forward();
  }
  if (data == "LS")
  {
    Serial.println(F("Left"));
    Left();
  }
  if (data == "RS")
  {
    Serial.println(F("Right"));
    Right();
  }
  if (data == "BS")
  {
    Serial.println(F("Reverse"));
    Reverse();
  }
  if (data == "S")
  {
    Serial.println(F("Stop"));
    Stop();
  }
  if (data == "X")
  {
    flag.HCSR04Flag=0;
    Serial.println(F("Stop"));
    Stop();
    flag.back_light_Flag=2;
    flag.HCSR04Flag=0;
  }
  if (data == "x")
  {
    Serial.println(F("Stop"));
    Stop();
    flag.back_light_Flag=0;
    flag.HCSR04Flag=1;
  }
  if (data == "FGFS")
  {
    //LF
    motors.rotate(motor1, 60, CCW);
    motors.rotate(motor2, 100, CCW);
  }
  if (data == "FIFS")
  {
    //RF
    motors.rotate(motor1, 100, CCW);
    motors.rotate(motor2, 60, CCW);
  }
  if (data == "BHBS")
  {
    //LB
    motors.rotate(motor1, 60, CW);
    motors.rotate(motor2, 100, CW);
  }
  if (data == "BJBS")
  {
    //RB
    motors.rotate(motor1, 100, CW);
    motors.rotate(motor2, 60, CW);
  }
  if (data == "U")
  {
    //backlight
    digitalWrite(back_light, HIGH);  
    flag.back_light_Flag=1;
    //Serial.println(F("light"));
  }
  if (data == "u")
  {
    //backlight
    digitalWrite(back_light, LOW);
    flag.back_light_Flag=0;
    //Serial.println(F("lightoff"));
  }
  if (data == "W")
  {
    digitalWrite(front_light, HIGH);  
    flag.front_light_Flag=1;
    //Serial.println(F("light"));
  }
  if (data == "w")
  {
    digitalWrite(front_light, LOW);
    flag.front_light_Flag=0;
    //Serial.println(F("lightoff"));
  }
}
//-------------------------------------------
void vUARTTask(void *pvParameters)
{
  (void)pvParameters;

  Serial.print(F("UARTTask at core:"));
  Serial.println(xPortGetCoreID());
  for (;;)
  {
    while (Serial.available() > 0)
    {
      Uart.c = Serial.read();
 
      if ((Uart.c == '\n') || (Uart.c == '\r'))
      { // End of line reached
        if (Uart.lineIndex > 0)
        { // Line is complete. Then execute!
          Uart.line[Uart.lineIndex] = '\0'; // Terminate string
          //Serial.println( F("Debug") );
          //Serial.println( Uart.inputString );
          processCommand(Uart.line);
          Uart.lineIndex = 0;
          Uart.inputString = "";
        }
        else
        {
          // Empty or comment line. Skip block.
        }
        Uart.lineIsComment = false;
        Uart.lineSemiColon = false;
        Serial.println(F("ok>"));
      }
      else
      {
        //Serial.println( c );
        if ((Uart.lineIsComment) || (Uart.lineSemiColon))
        {
          if (Uart.c == ')')
            Uart.lineIsComment = false; // End of comment. Resume line.
        }
        else
        {
          if (Uart.c == '/')
          { // Block delete not supported. Ignore character.
          }
          else if (Uart.c == '~')
          { // Enable comments flag and ignore all characters until ')' or EOL.
            Uart.lineIsComment = true;
          }
          else if (Uart.c == ';')
          {
            Uart.lineSemiColon = true;
          }
          else if (Uart.lineIndex >= LINE_BUFFER_LENGTH - 1)
          {
            Serial.println("ERROR - lineBuffer overflow");
            Uart.lineIsComment = false;
            Uart.lineSemiColon = false;
          }
          else if (Uart.c >= 'a' && Uart.c <= 'z')
          { // Upcase lowercase
            Uart.line[Uart.lineIndex] = Uart.c - 'a' + 'A';
            Uart.lineIndex = Uart.lineIndex + 1;
            Uart.inputString += (char)(Uart.c - 'a' + 'A');
          }
          else
          {
            Uart.line[Uart.lineIndex] = Uart.c;
            Uart.lineIndex = Uart.lineIndex + 1;
            Uart.inputString += Uart.c;
          }
        }
      }
    } //while (Serial.available() > 0)
    while (SerialBT.available())
    {
      flag.L298NFlag=1;
      String BTdata = SerialBT.readString();
      Stop();
      Serial.println(BTdata);
      BTprocessCommand(BTdata); // do something with the command
    }//while (BT.available())
    vTaskDelay(1);
  }
}
void vFunctionTask(void *pvParameters)
{
  (void)pvParameters;

  Serial.print(F("FunctionTask at core:"));
  Serial.println(xPortGetCoreID());
  for (;;) // A Task shall never return or exit.
  {
    if(flag.HCSR04Flag==1)
    {
      currentMillis = millis();
      myservo.write(90);
      digitalWrite(TRIGPIN_PIN, LOW);  
      delayMicroseconds(2);  
      digitalWrite(TRIGPIN_PIN, HIGH);
      delayMicroseconds(10);
      digitalWrite(TRIGPIN_PIN, LOW);  
      duration= pulseIn(ECHO_PIN, HIGH);
      distance= duration/29/2;
      if (duration==0)
      {
        Serial.println("No pulse is from sensor");
      }
      else
      {
        Serial.print("Ultrasonic sensor is shown distance:");
        Serial.print(distance);
        Serial.println("cm");
        Serial.print(distanceR-distanceL);
        Serial.println("cm");
      }
    }
    if(flag.HCSR04Flag==2)  //lookRight
    {
      myservo.write(20);
      digitalWrite(TRIGPIN_PIN, LOW);  
      delayMicroseconds(2);  
      digitalWrite(TRIGPIN_PIN, HIGH);
      delayMicroseconds(10);  
      digitalWrite(TRIGPIN_PIN, LOW);  
      duration= pulseIn(ECHO_PIN, HIGH);
      distanceR= duration/29/2;
      if (duration==0)
      {
        Serial.println("No pulse is from sensor");
      }
      else
      {
        //Serial.print("Ultrasonic sensor is shown distanceR:");
        //Serial.print(distanceR);
        //Serial.println("cm");
      }
    }
    if(flag.HCSR04Flag==3)  //lookLeft
    {
      myservo.write(160);
      digitalWrite(TRIGPIN_PIN, LOW);  
      delayMicroseconds(2);  
      digitalWrite(TRIGPIN_PIN, HIGH);
      delayMicroseconds(10);  
      digitalWrite(TRIGPIN_PIN, LOW);  
      duration= pulseIn(ECHO_PIN, HIGH);
      distanceL= duration/29/2;
      if (duration==0)
      {
        Serial.println("No pulse is from sensor");
      }
      else
      {
        //Serial.print("Ultrasonic sensor is shown distanceL:");
        //Serial.print(distanceL);
        //Serial.println("cm");
      }
    }
    vTaskDelay(1);
  }
}